
Proving ground
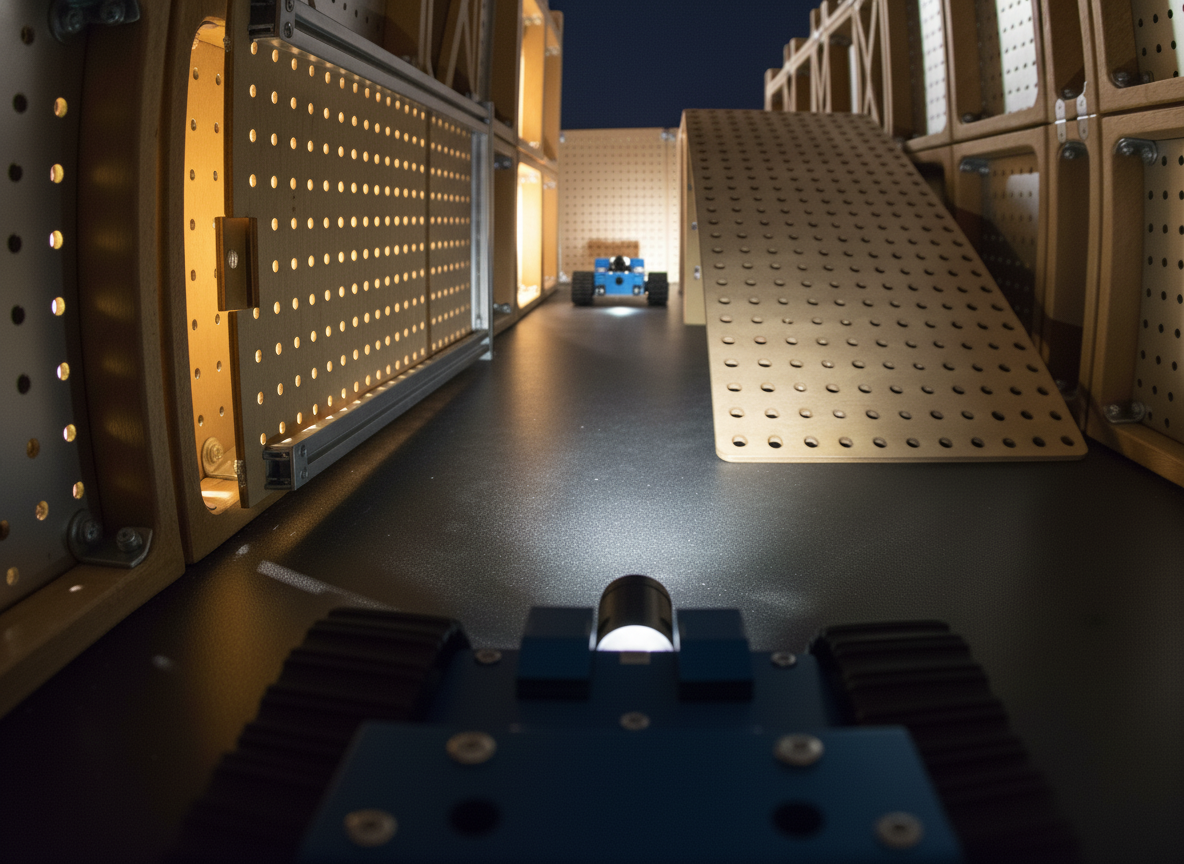
A secure, purpose-built outdoor infrastructure for teleoperated and autonomous robotics. Step beyond sterile private testbeds into a living, non-sterile environment—operating, testing, and coexisting alongside other machines, real operators, and shared infrastructure.
The hardware foundation
ESP32-P4 architecture
The official Juvantia Robulus Platform board is built on the ESP32-P4 chip, providing vehicle control, telemetry streaming, and park mesh networking out of the box.
Bring your own compute
Keep your ROS2 stacks and autonomy algorithms. Connect your own Nvidia Jetson, Raspberry Pi, LiDAR, or neural accelerators directly to the P4 vehicle bridge.
Bespoke designs
Deploy on our reference carrier board or integrate your own hardware. For proprietary research or unique industrial form factors, we are open to discussing bespoke solutions.
Industry & academia
Tailored deployment paths eliminating proving ground barriers for both commercial product development and scientific research.
Hardware companies & startups
Accelerate your cycle from laboratory prototyping to field validation without investing hundreds of thousands into private testing infrastructure. Deploy prototypes directly to the park and operate 24/7 in non-sterile outdoor conditions:
Zero Facility CAPEX
No land acquisition, perimeter fencing, weatherproofing, or base-station network overhead.
Continuous Reliability Runs
Stress-test drivetrains, thermal dissipation, suspension, and battery wear across hundreds of hours.
Global Remote Demos
Demonstrate active prototypes to investors and enterprise buyers worldwide via Operator Deck.
Dedicated Domus Garages
Private workshop sectors with continuous power, wired telemetry links, and secure hardware storage.
University laboratories & research
Provide research departments and students with direct remote access to outdoor robotics experimentation without physical relocation. Test autonomy stacks and gather authentic sensor datasets under genuine physics:
Sim-to-Real Benchmarking
Test Isaac Sim and Gazebo models against real moisture, wheel slip, loose stones, and lighting shifts.
Physical AI Dataset Gathering
Collect synchronised camera, IMU, and BLE beacon streams with authentic physical sensory noise.
Cross-Campus Competitions
Host remote student hackathons, teleoperation trials, and gripper challenges on shared park hardware.
Open Protocol Architecture
Deploy experimental firmware on ESP32 or official Juvantia PCBs via Web-Serial and WSS interfaces.